model::SweepPlane< LineType, dim > Struct Template Reference
#include <SweepPlane.h>
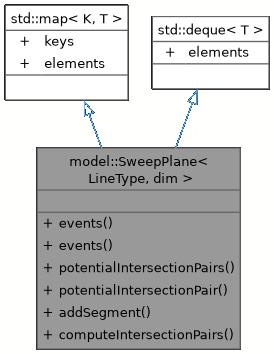
Inheritance diagram for model::SweepPlane< LineType, dim >:
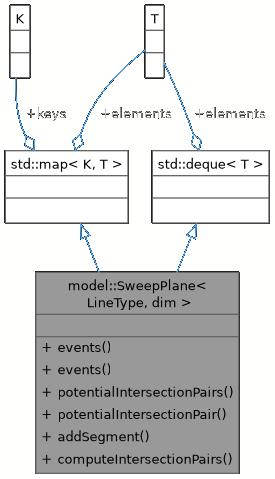
Collaboration diagram for model::SweepPlane< LineType, dim >:
Public Types | |
| typedef std::map< typename LineType::KeyType, const LineType * > | EventMapType |
| typedef std::map< float, std::pair< EventMapType, EventMapType > > | EventContainerType |
| typedef std::deque< std::pair< const LineType *, const LineType * > > | IntersectionPairContainerType |
Public Member Functions | |
| const EventContainerType & | events () const |
| EventContainerType & | events () |
| const IntersectionPairContainerType & | potentialIntersectionPairs () const |
| const std::pair< const LineType *, const LineType * > & | potentialIntersectionPair (const size_t &k) const |
| void | addSegment (const double &xStart, const double &xEnd, const LineType &line) |
| void | computeIntersectionPairs () |
Detailed Description
template<typename LineType, int dim>
struct model::SweepPlane< LineType, dim >
struct model::SweepPlane< LineType, dim >
https://en.wikipedia.org/wiki/Bentley–Ottmann_algorithm
Definition at line 27 of file SweepPlane.h.
Member Typedef Documentation
◆ EventContainerType
template<typename LineType, int dim>
| typedef std::map<float,std::pair<EventMapType,EventMapType> > model::SweepPlane< LineType, dim >::EventContainerType |
Definition at line 34 of file SweepPlane.h.
◆ EventMapType
template<typename LineType, int dim>
| typedef std::map<typename LineType::KeyType,const LineType*> model::SweepPlane< LineType, dim >::EventMapType |
Definition at line 33 of file SweepPlane.h.
◆ IntersectionPairContainerType
template<typename LineType, int dim>
| typedef std::deque<std::pair<const LineType*,const LineType*> > model::SweepPlane< LineType, dim >::IntersectionPairContainerType |
Definition at line 35 of file SweepPlane.h.
Member Function Documentation
◆ addSegment()
template<typename LineType, int dim>
|
inline |
Definition at line 59 of file SweepPlane.h.
◆ computeIntersectionPairs()
template<typename LineType, int dim>
|
inline |
Definition at line 72 of file SweepPlane.h.
◆ events() [1/2]
template<typename LineType, int dim>
|
inline |
Definition at line 43 of file SweepPlane.h.
◆ events() [2/2]
template<typename LineType, int dim>
|
inline |
Definition at line 37 of file SweepPlane.h.
◆ potentialIntersectionPair()
template<typename LineType, int dim>
|
inline |
Definition at line 53 of file SweepPlane.h.
◆ potentialIntersectionPairs()
template<typename LineType, int dim>
|
inline |
Definition at line 48 of file SweepPlane.h.
The documentation for this struct was generated from the following file:
Generated by
 1.15.0