#include <PlanesIntersection.h>
Public Types | |
| typedef Eigen::Matrix< double, Eigen::Dynamic, Eigen::Dynamic > | MatrixDimDynamic |
| typedef Eigen::Matrix< double, dim, 1 > | VectorDim |
| typedef Eigen::JacobiSVD< MatrixDimDynamic > | SVDsolverType |
Public Member Functions | |
| PlanesIntersection (const MatrixDimDynamic &N, const MatrixDimDynamic &P, const double &tol=FLT_EPSILON) | |
| std::pair< bool, VectorDim > | snap (const VectorDim &x) const |
Public Attributes | |
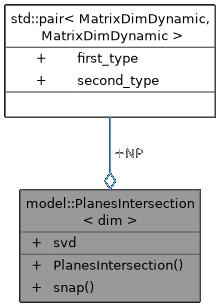
| const std::pair< MatrixDimDynamic, MatrixDimDynamic > | NP |
| const SVDsolverType | svd |
Detailed Description
struct model::PlanesIntersection< dim >
Definition at line 20 of file PlanesIntersection.h.
Member Typedef Documentation
◆ MatrixDimDynamic
| typedef Eigen::Matrix<double,Eigen::Dynamic,Eigen::Dynamic> model::PlanesIntersection< dim >::MatrixDimDynamic |
Definition at line 23 of file PlanesIntersection.h.
◆ SVDsolverType
| typedef Eigen::JacobiSVD<MatrixDimDynamic> model::PlanesIntersection< dim >::SVDsolverType |
Definition at line 25 of file PlanesIntersection.h.
◆ VectorDim
| typedef Eigen::Matrix<double,dim,1> model::PlanesIntersection< dim >::VectorDim |
Definition at line 24 of file PlanesIntersection.h.
Constructor & Destructor Documentation
◆ PlanesIntersection()
| model::PlanesIntersection< dim >::PlanesIntersection | ( | const MatrixDimDynamic & | N, |
| const MatrixDimDynamic & | P, | ||
| const double & | tol = FLT_EPSILON ) |
Definition at line 22 of file PlanesIntersection.cpp.
Member Function Documentation
◆ snap()
| std::pair< bool, typename PlanesIntersection< dim >::VectorDim > model::PlanesIntersection< dim >::snap | ( | const VectorDim & | x | ) | const |
- Parameters
-
[in] x point to be snapped to the intersection between the planes
- Returns
- a pair where pair.first is true if snapping was successful, and pair.second is the position of the snapped point
The snapped point y minimizes the distance from x constrained to y belonging to the planes. Using lgrange multipliers, the solution is y=x-N*lam, where lam is a vector of Lagrance multipliers solving N^T*N lam = b, and b_k = n_k(x-P_k), where n_k and P_k are the normal and origin of the k0th plane. We solve this using svd, hence we get the "best solution", which may not actually satisfy the contraints if the planes are not intersecting. Hence we check that the solution actually belongs to the intersectoin between the planes before returning it.
Definition at line 29 of file PlanesIntersection.cpp.
Member Data Documentation
◆ NP
| const std::pair<MatrixDimDynamic,MatrixDimDynamic> model::PlanesIntersection< dim >::NP |
Definition at line 27 of file PlanesIntersection.h.
◆ svd
| const SVDsolverType model::PlanesIntersection< dim >::svd |
Definition at line 28 of file PlanesIntersection.h.
The documentation for this struct was generated from the following files:
Generated by
 1.15.0