#include <SplineSegment.h>
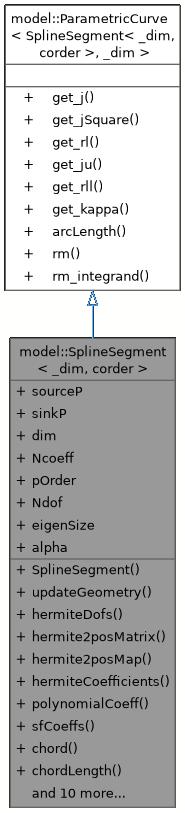
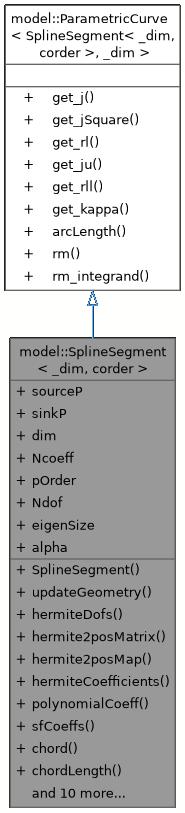
Public Types | |
| typedef Eigen::Matrix< double, 1, Ncoeff > | RowNcoeff |
| typedef Eigen::Matrix< double, 1, Ncoeff-1 > | RowNcoeffu |
| typedef Eigen::Matrix< double, 1, Ncoeff-2 > | RowNcoeffuu |
| typedef Eigen::Matrix< double, Ncoeff, Ncoeff > | MatrixNcoeff |
| typedef Eigen::Matrix< double, Ncoeff, dim > | MatrixNcoeffDim |
| typedef Eigen::Matrix< double, Ndof, 1 > | VectorNdof |
| typedef Eigen::Matrix< double, dim, dim > | MatrixDim |
| typedef Eigen::Matrix< double, dim, 1 > | VectorDim |
| typedef Eigen::Matrix< double, dim, Ndof > | MatrixDimNdof |
| typedef Eigen::Matrix< double, Ncoeff, 1 > | VectorNcoeff |
| typedef Eigen::Matrix< double, Ndof, Ndof > | MatrixNdof |
| typedef SplineSegmentBase< dim, corder > | SplineSegmentBaseType |
| typedef ParametricCurve< SplineSegment< _dim, corder >, dim > | ParametricCurveType |
Public Member Functions | |
| SplineSegment (const VectorDim &sourceP_in, const VectorDim &sinkP_in) | |
| void | updateGeometry () |
| MatrixNcoeffDim | hermiteDofs () const |
| std::pair< Eigen::Matrix< double, Ncoeff, Eigen::Dynamic >, Eigen::Matrix< double, Eigen::Dynamic, dim > > | hermite2posMatrix () const |
| SplineSegmentBaseType::H2PmapType | hermite2posMap () const |
| Eigen::Matrix< double, dim, Ncoeff > | hermiteCoefficients () const |
| Eigen::Matrix< double, dim, Ncoeff > | polynomialCoeff () const |
| MatrixNcoeff | sfCoeffs () const |
| const VectorDim & | chord () const |
| const double & | chordLength () const |
| const double & | chordLengthSquared () const |
| const VectorDim & | unitDirection () const |
| double | parametricChordLength () const |
| VectorDim | get_r (const double &u) const |
| RowNcoeff | sf (const double &u) const |
| VectorDim | get_ru (const double &uin) const |
| VectorDim | get_rmu (const double &uin) const |
| VectorDim | get_ruu (const double &uin) const |
| VectorDim | get_rmumu (const double &uin) const |
| std::pair< double, std::pair< double, VectorDim > > | closestPoint (const VectorDim &P0) const |
| Public Member Functions inherited from model::ParametricCurve< SplineSegment< _dim, corder >, _dim > | |
| double | get_j (const double &u) const |
| double | get_jSquare (const double &u) const |
| VectorDim | get_rl (const double &u) const |
| double | get_ju (const double &u) const |
| VectorDim | get_rll (const double &u) const |
| double | get_kappa (const double &u) const |
| the scalar curvature | |
| double | arcLength () const |
| VectorDim | rm () const |
| VectorDim | rm_integrand (const double &u) const |
Public Attributes | |
| const VectorDim & | sourceP |
| const VectorDim & | sinkP |
Static Public Attributes | |
| static constexpr int | dim = _dim |
| static constexpr int | Ncoeff = 2*(corder+1) |
| static constexpr int | pOrder = 2*corder+1 |
| static constexpr int | Ndof = dim*Ncoeff |
| static constexpr int | eigenSize =pOrder*pOrder |
| static double | alpha |
Detailed Description
class model::SplineSegment< _dim, corder >
A SplineSegment is a special kind of parametric curve where the position vector can be written as:
r(u)=N(u)*q
where N(u) is a (dim x NdofXsegment) matrix of shape functions and q is a (NdofXsegment x 1) column vector of degrees of freedom, where NdofXsegment= dim x n and n=porder+1 is the number of shape functions:
| N1  0  0              Nn  0  0 |
N= |  0 N1  0   ...  0 Nn  0 |
|  0  0 N1               0  0 Nn |
Each shape function is a porder:
[N1 ... Nn]= [1 u ... n^porder] * SFC
where SFC is a n x n matrix of shape function coefficients that in general dependes on the knot vector. It's posible to take advantage of this particular form of shape functions to calculate ruu and ru therefore these functions are redefined here (virtual in ParametricCurve) and the flow chart of their implementation is shown below:
make_UPOWuu()     make_UPOWu()  make_UPOW()
^                                 ^                             ^
|                                 |                             |
make_SFuu()       make_SFu()    make_SF()
^                                 ^                             ^
|                                 |                             |
make_Nuu()                make_Nu()             make_N()
^                                 ^                             ^
|                                 |                             |
make_ruu()                make_ru()             make_r()        (this level is virtual in ParametricCurve)
Definition at line 73 of file SplineSegment.h.
Member Typedef Documentation
◆ MatrixDim
| typedef Eigen::Matrix<double,dim,dim> model::SplineSegment< _dim, corder >::MatrixDim |
Definition at line 94 of file SplineSegment.h.
◆ MatrixDimNdof
| typedef Eigen::Matrix<double, dim, Ndof> model::SplineSegment< _dim, corder >::MatrixDimNdof |
Definition at line 96 of file SplineSegment.h.
◆ MatrixNcoeff
| typedef Eigen::Matrix<double, Ncoeff, Ncoeff> model::SplineSegment< _dim, corder >::MatrixNcoeff |
Definition at line 91 of file SplineSegment.h.
◆ MatrixNcoeffDim
| typedef Eigen::Matrix<double, Ncoeff, dim> model::SplineSegment< _dim, corder >::MatrixNcoeffDim |
Definition at line 92 of file SplineSegment.h.
◆ MatrixNdof
| typedef Eigen::Matrix<double,Ndof,Ndof> model::SplineSegment< _dim, corder >::MatrixNdof |
Definition at line 98 of file SplineSegment.h.
◆ ParametricCurveType
| typedef ParametricCurve<SplineSegment<_dim,corder>,dim> model::SplineSegment< _dim, corder >::ParametricCurveType |
Definition at line 100 of file SplineSegment.h.
◆ RowNcoeff
| typedef Eigen::Matrix<double, 1, Ncoeff> model::SplineSegment< _dim, corder >::RowNcoeff |
Definition at line 88 of file SplineSegment.h.
◆ RowNcoeffu
| typedef Eigen::Matrix<double, 1, Ncoeff-1> model::SplineSegment< _dim, corder >::RowNcoeffu |
Definition at line 89 of file SplineSegment.h.
◆ RowNcoeffuu
| typedef Eigen::Matrix<double, 1, Ncoeff-2> model::SplineSegment< _dim, corder >::RowNcoeffuu |
Definition at line 90 of file SplineSegment.h.
◆ SplineSegmentBaseType
| typedef SplineSegmentBase<dim,corder> model::SplineSegment< _dim, corder >::SplineSegmentBaseType |
Definition at line 99 of file SplineSegment.h.
◆ VectorDim
| typedef Eigen::Matrix<double,dim,1> model::SplineSegment< _dim, corder >::VectorDim |
Definition at line 95 of file SplineSegment.h.
◆ VectorNcoeff
| typedef Eigen::Matrix<double,Ncoeff,1> model::SplineSegment< _dim, corder >::VectorNcoeff |
Definition at line 97 of file SplineSegment.h.
◆ VectorNdof
| typedef Eigen::Matrix<double, Ndof,1> model::SplineSegment< _dim, corder >::VectorNdof |
Definition at line 93 of file SplineSegment.h.
Constructor & Destructor Documentation
◆ SplineSegment()
|
inline |
Constructor with Nodes and flow
Definition at line 122 of file SplineSegment.h.
Member Function Documentation
◆ chord()
|
inline |
- Returns
- the chord vector (source -> sink)
Definition at line 198 of file SplineSegment.h.
◆ chordLength()
|
inline |
- Returns
- the length of the chord vector
Definition at line 205 of file SplineSegment.h.
◆ chordLengthSquared()
|
inline |
- Returns
- the length of the chord vector
Definition at line 212 of file SplineSegment.h.
◆ closestPoint()
|
inline |
- Parameters
-
[in] P0 reference point
- Returns
- The closesest point to P0 along this segment. The return value is a pair, where pair.first is the parameter value u, and pair.second is the position P of the closest point, so that get_r(u)=P.
Definition at line 278 of file SplineSegment.h.
◆ get_r()
|
inline |
- Returns
- The position vector at parameter u
- Parameters
-
[in] u the parametrization variable in [0:1] \[ \mathbf{r} = \mathbf{q}\mathbf{H}\mathbf{u} \\ r_i = q_{ik}H_{km}u^{m} = q_{ik} N_k \]
with i=0..dim-1, k,m = 0... Ncoeff ACTUALLY IN THE CODE WE HAVE THE TRANSPOSE OF THIS !!!!
Definition at line 232 of file SplineSegment.h.
◆ get_rmu()
|
inline |
Definition at line 260 of file SplineSegment.h.
◆ get_rmumu()
|
inline |
Definition at line 272 of file SplineSegment.h.
◆ get_ru()
|
inline |
Definition at line 254 of file SplineSegment.h.
◆ get_ruu()
|
inline |
Definition at line 266 of file SplineSegment.h.
◆ hermite2posMap()
|
inline |
Definition at line 157 of file SplineSegment.h.
◆ hermite2posMatrix()
|
inline |
Definition at line 151 of file SplineSegment.h.
◆ hermiteCoefficients()
|
inline |
Definition at line 163 of file SplineSegment.h.
◆ hermiteDofs()
|
inline |
Definition at line 145 of file SplineSegment.h.
◆ parametricChordLength()
|
inline |
- Returns
- the length of the chord vector to the power alpha
Definition at line 226 of file SplineSegment.h.
◆ polynomialCoeff()
|
inline |
The matrix of coefficients of the polynomial associated to this SplineSegmentBase. If C=polynomialCoeff() then the polynomial is: P(u)=C.col(0)+u*C.col(1)+u^2*C.col(2)+...
Definition at line 169 of file SplineSegment.h.
◆ sf()
|
inline |
Definition at line 246 of file SplineSegment.h.
◆ sfCoeffs()
|
inline |
Definition at line 178 of file SplineSegment.h.
◆ unitDirection()
|
inline |
- Returns
- the chord vector (source -> sink)
Definition at line 219 of file SplineSegment.h.
◆ updateGeometry()
|
inline |
Definition at line 136 of file SplineSegment.h.
Member Data Documentation
◆ alpha
|
static |
Definition at line 118 of file SplineSegment.h.
◆ dim
|
staticconstexpr |
Definition at line 82 of file SplineSegment.h.
◆ eigenSize
|
staticconstexpr |
Definition at line 86 of file SplineSegment.h.
◆ Ncoeff
|
staticconstexpr |
Definition at line 83 of file SplineSegment.h.
◆ Ndof
|
staticconstexpr |
Definition at line 85 of file SplineSegment.h.
◆ pOrder
|
staticconstexpr |
Definition at line 84 of file SplineSegment.h.
◆ sinkP
| const VectorDim& model::SplineSegment< _dim, corder >::sinkP |
Definition at line 105 of file SplineSegment.h.
◆ sourceP
| const VectorDim& model::SplineSegment< _dim, corder >::sourceP |
Definition at line 104 of file SplineSegment.h.
The documentation for this class was generated from the following file:
Generated by
 1.15.0